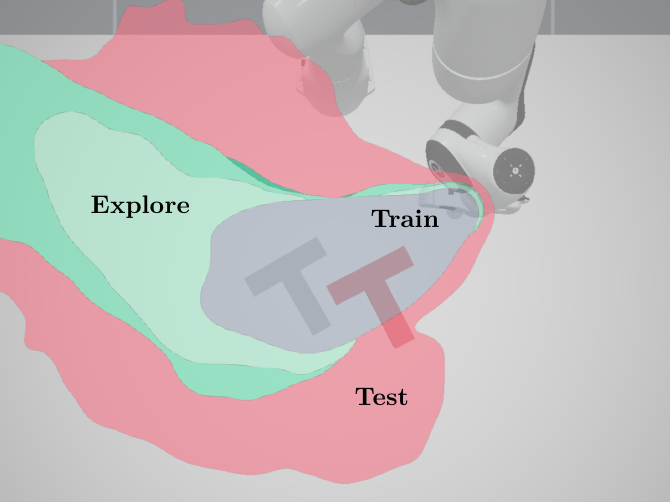
Training Controllable World Models via Action Influence Maximization
Conference on Robot Learning (CoRL), 2026
Hi! I am a PhD student at Princeton advised by Prof. Ani Majumdar. I'm interested in building robots that can do any task, and training video world models that are fast, generalizable, and can learn from diverse interaction data. Previously, I interned at Toyota Research Institute (TRI), and received my B.S. in CS and ECE from Cornell University, where I worked with Prof. Hadas Kress-Gazit and Prof. Bharath Hariharan.
📮 tenny [dot] yin [at] princeton [dot] edu
Google Scholar / X / GitHub / LinkedIn
Conference on Robot Learning (CoRL), 2026
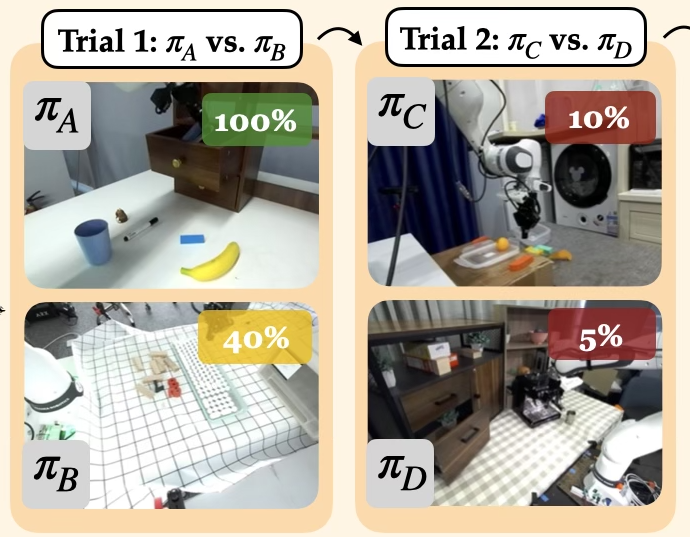
Conference on Robot Learning (CoRL), 2026
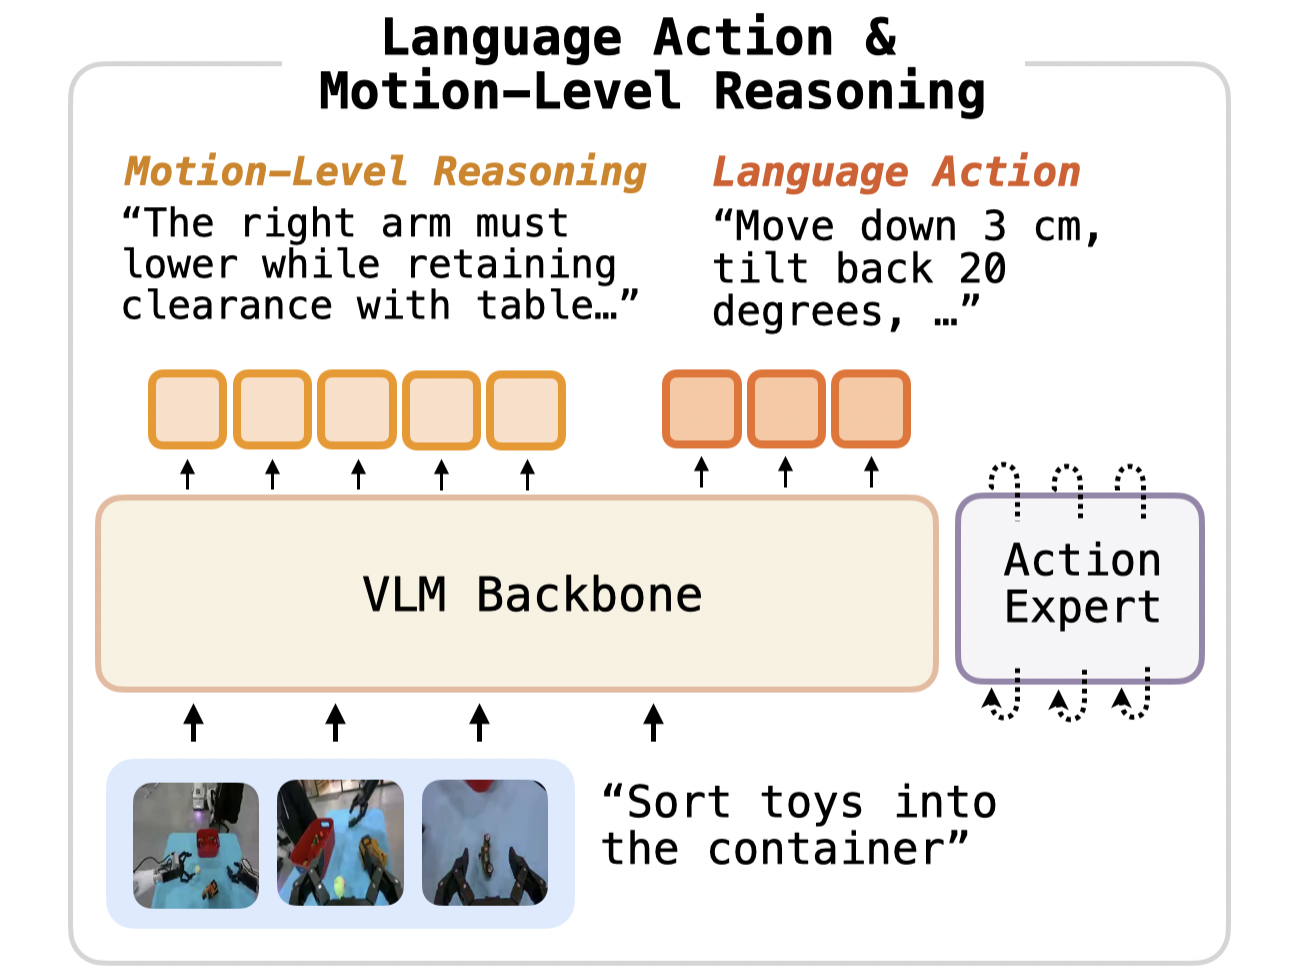
arXiv preprint, 2026
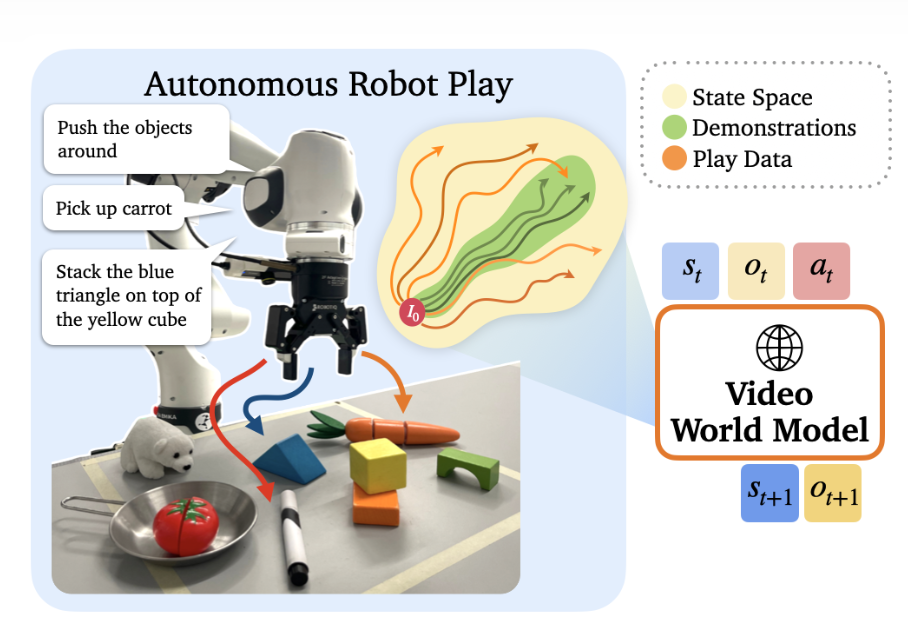
Conference on Robot Learning (CoRL), 2026
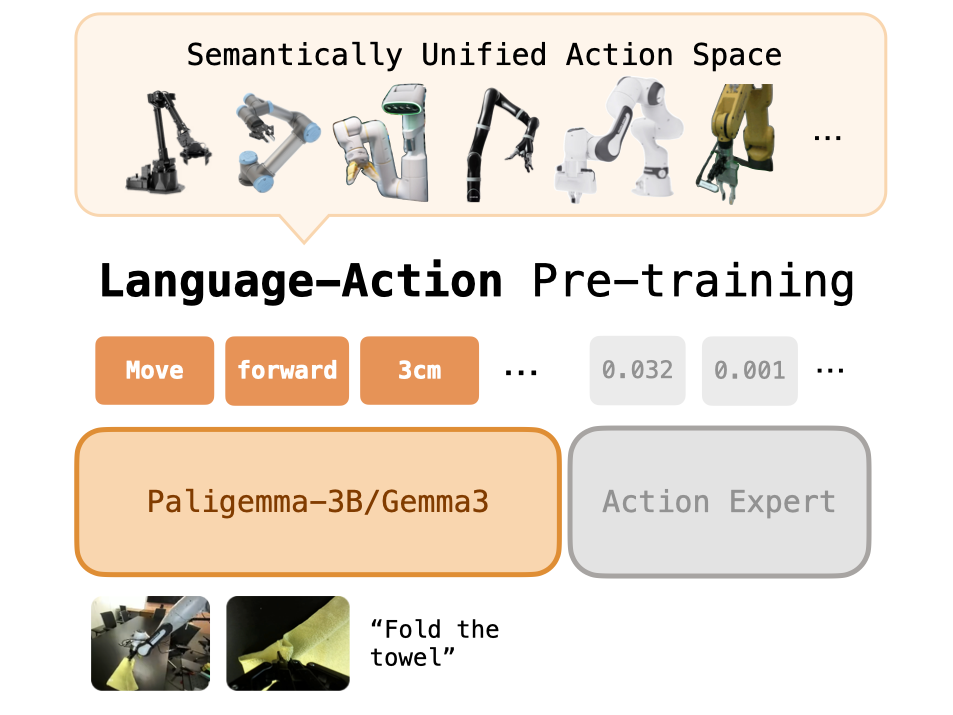
Robotics: Science and Systems (RSS), 2026
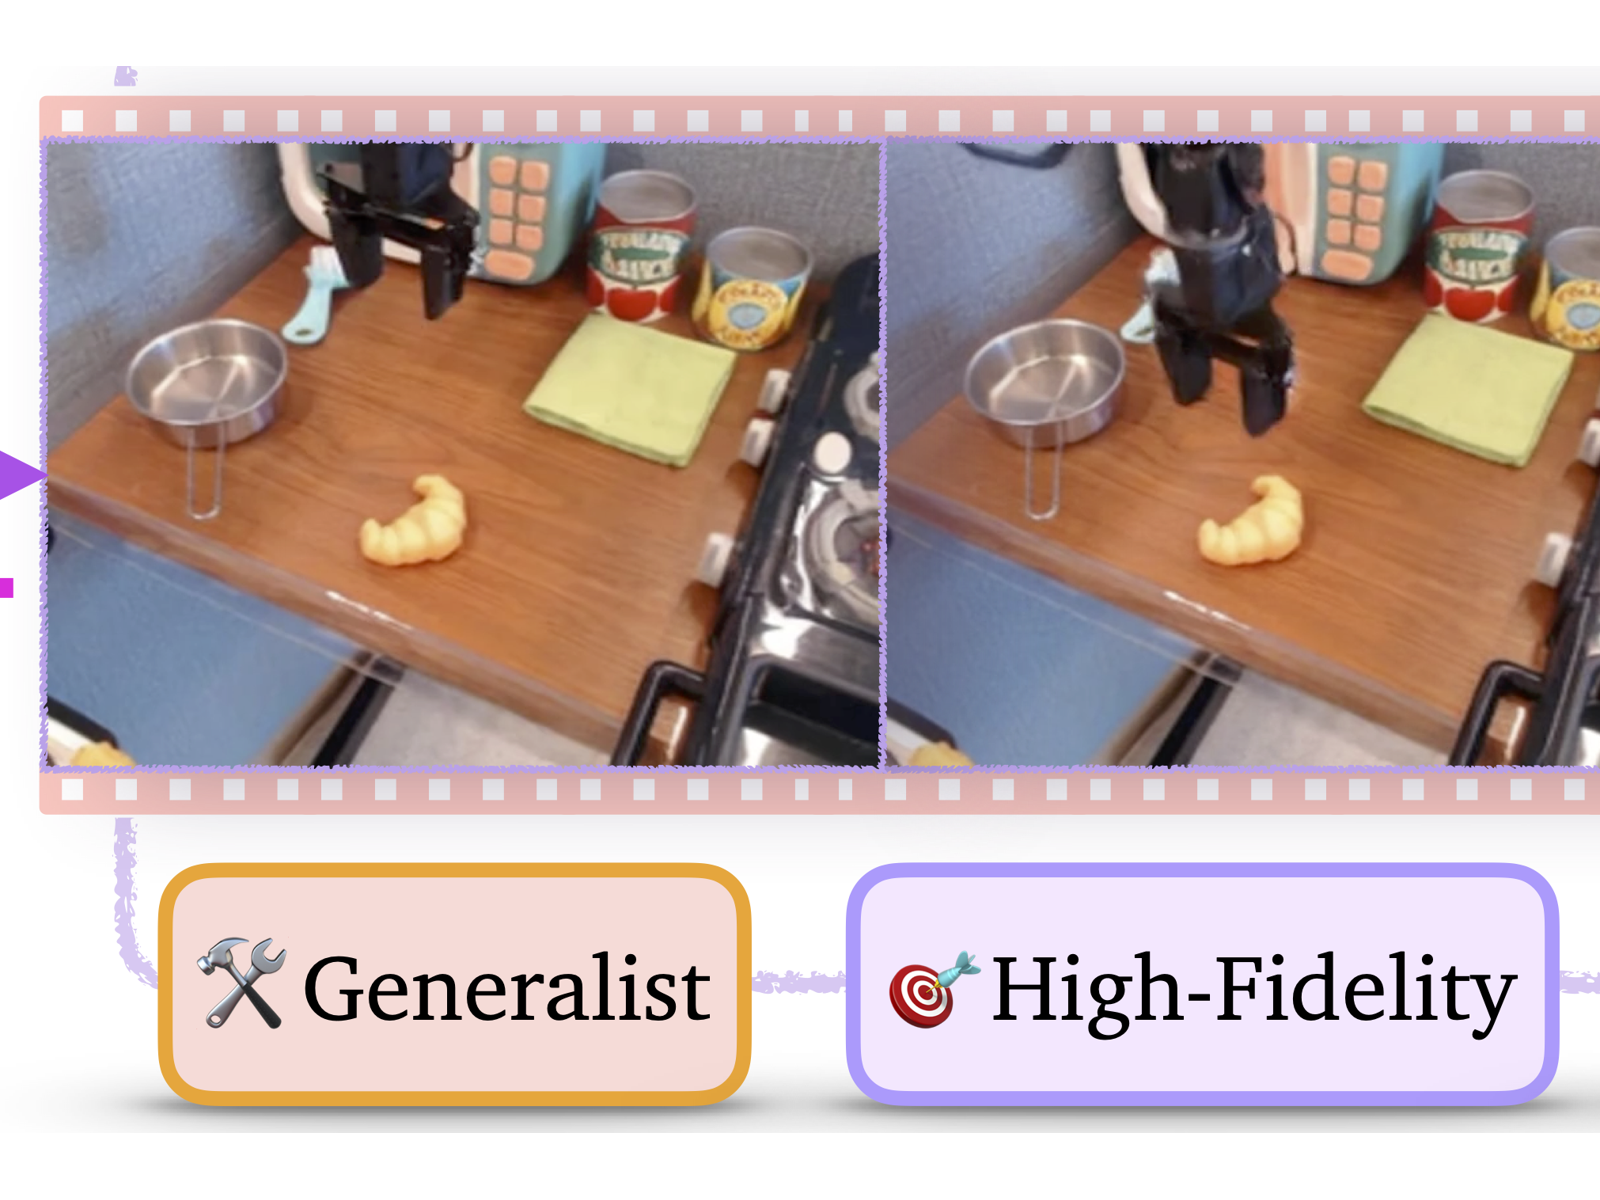
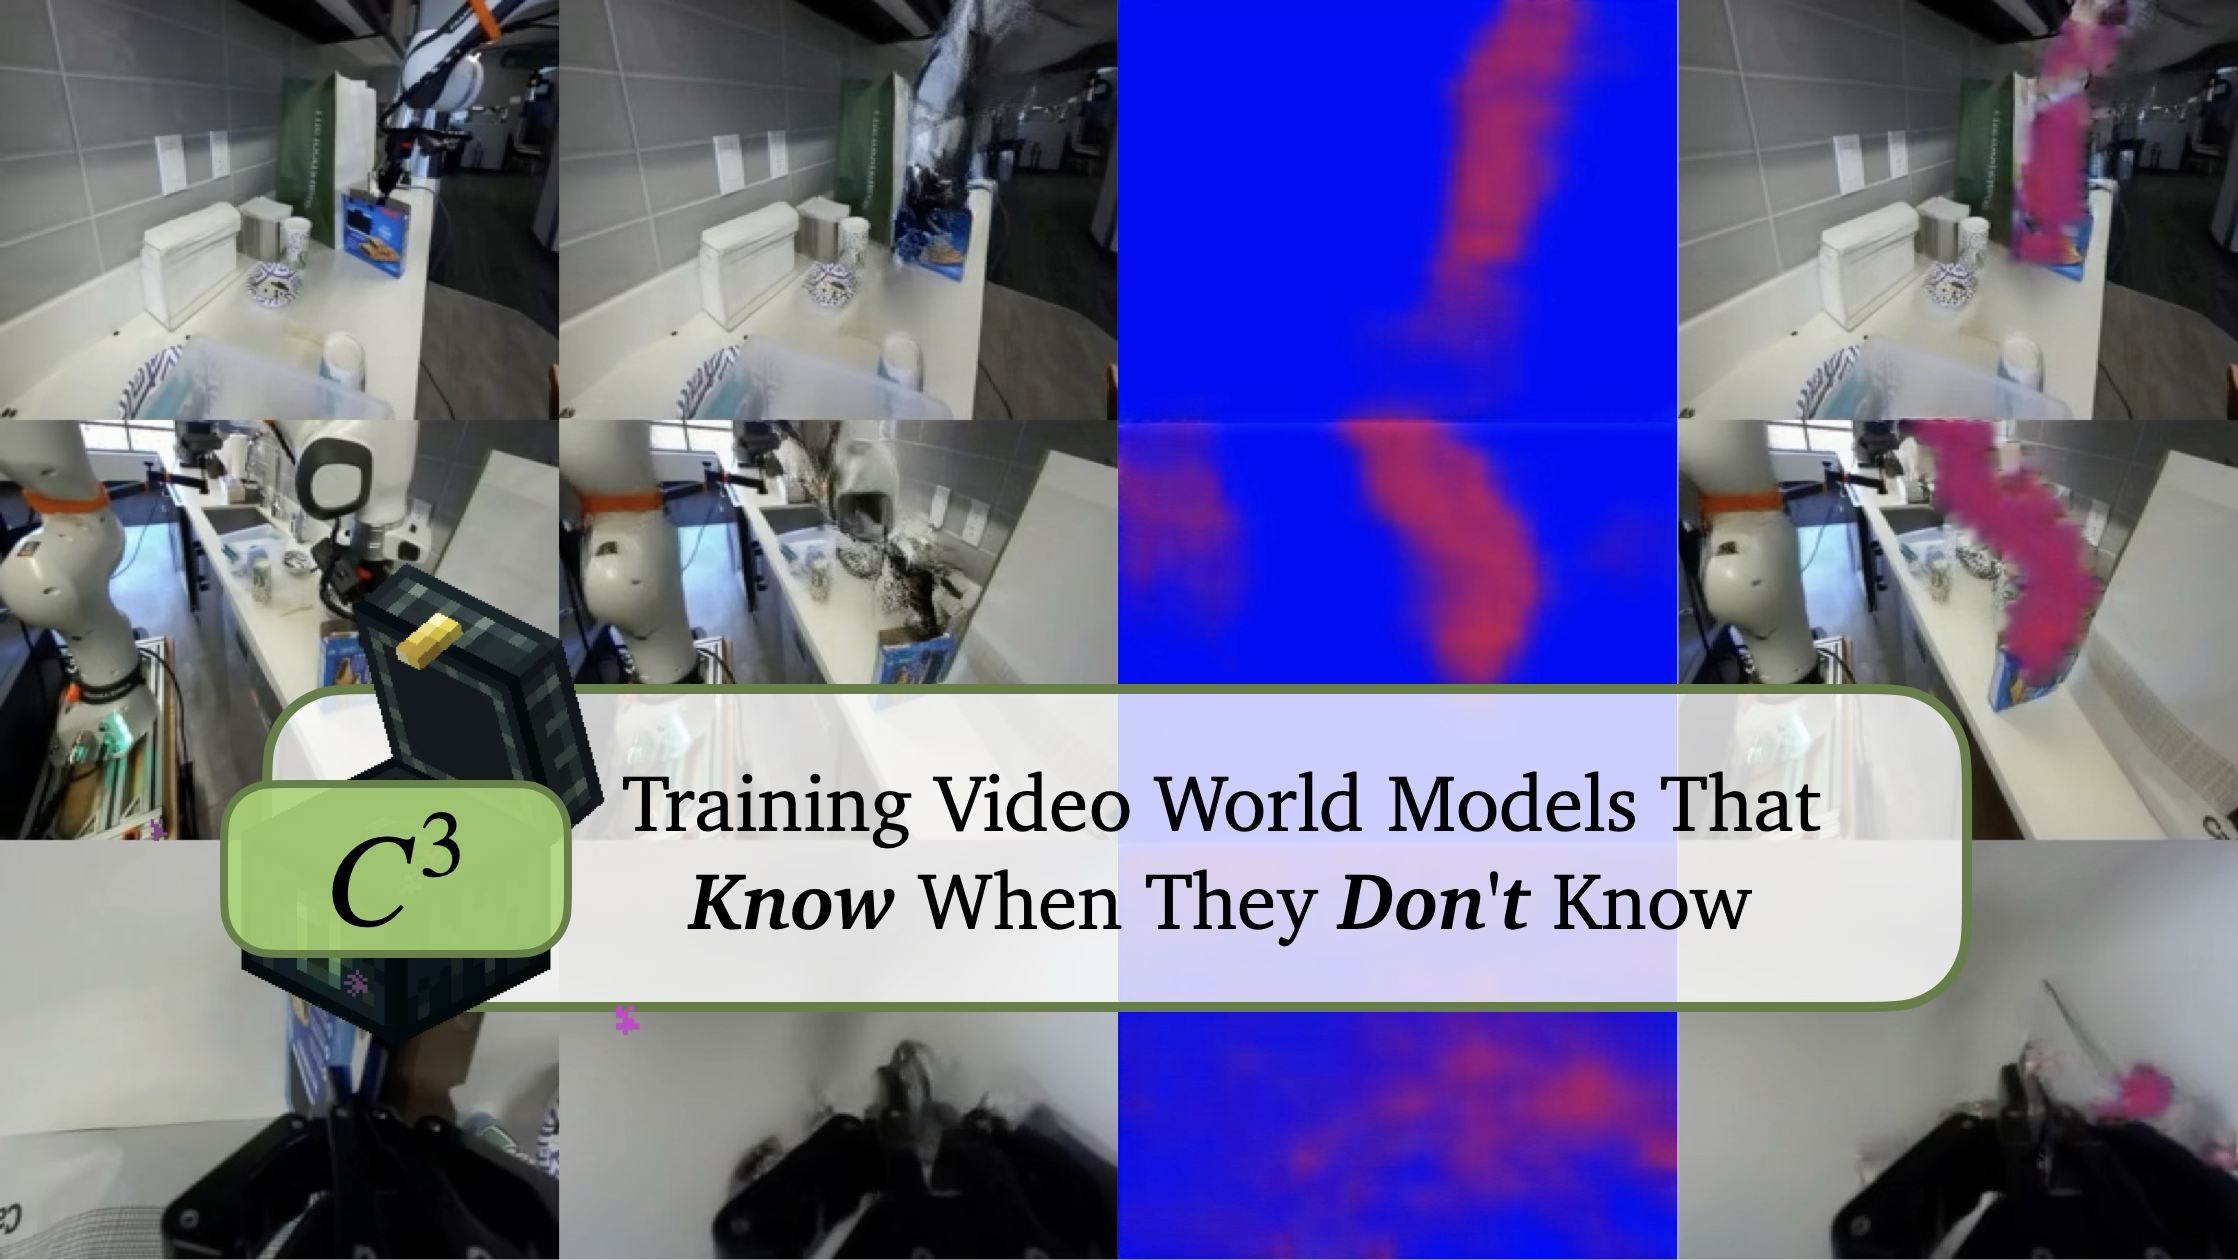
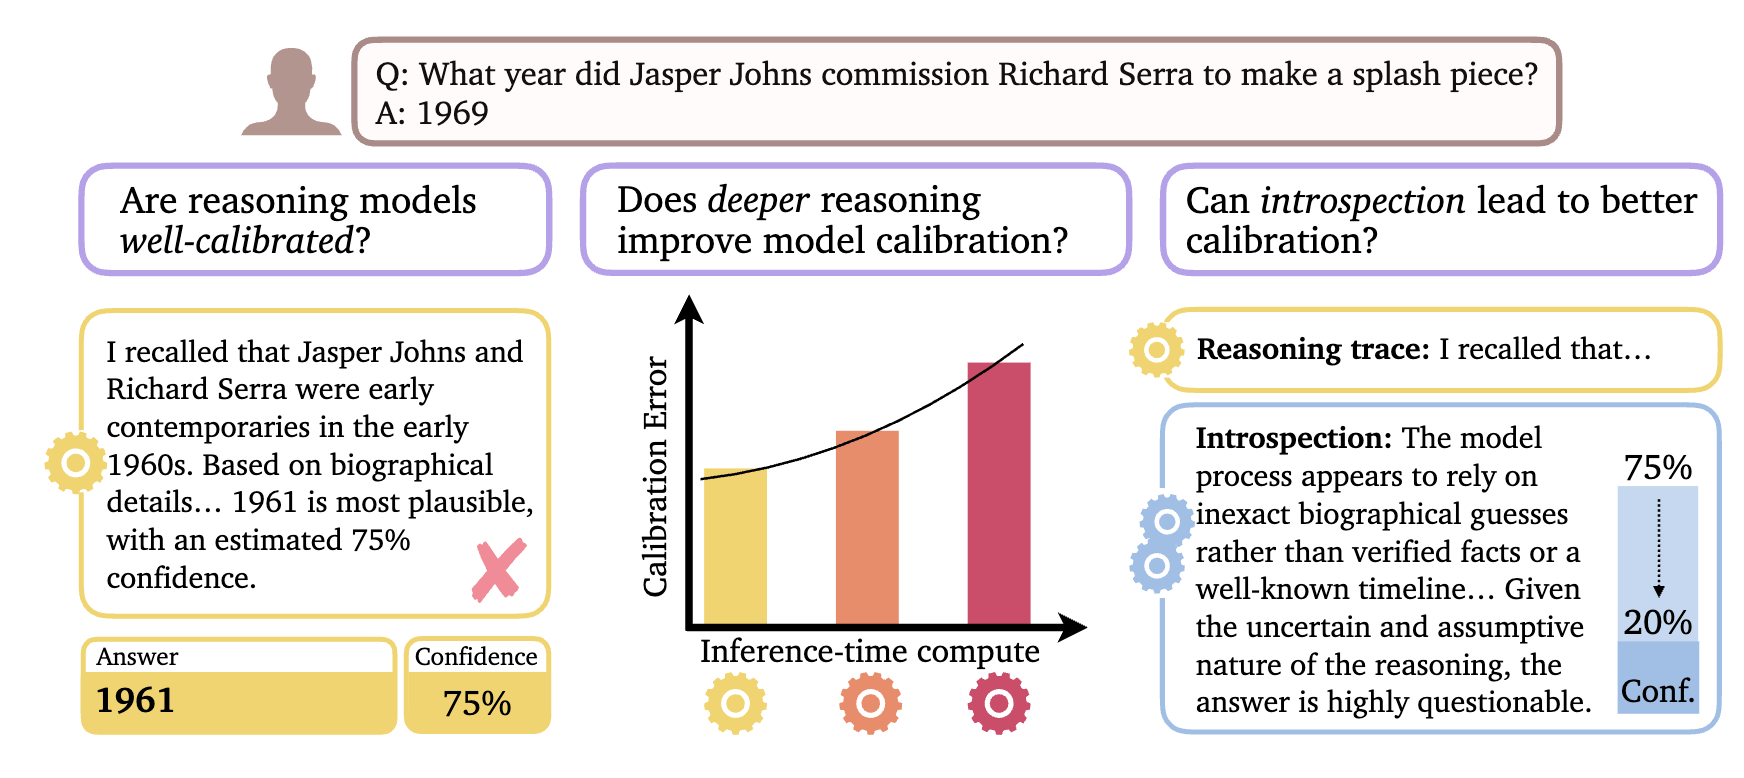
Conference of the European Chapter of the Association for Computational Linguistics (EACL), 2025
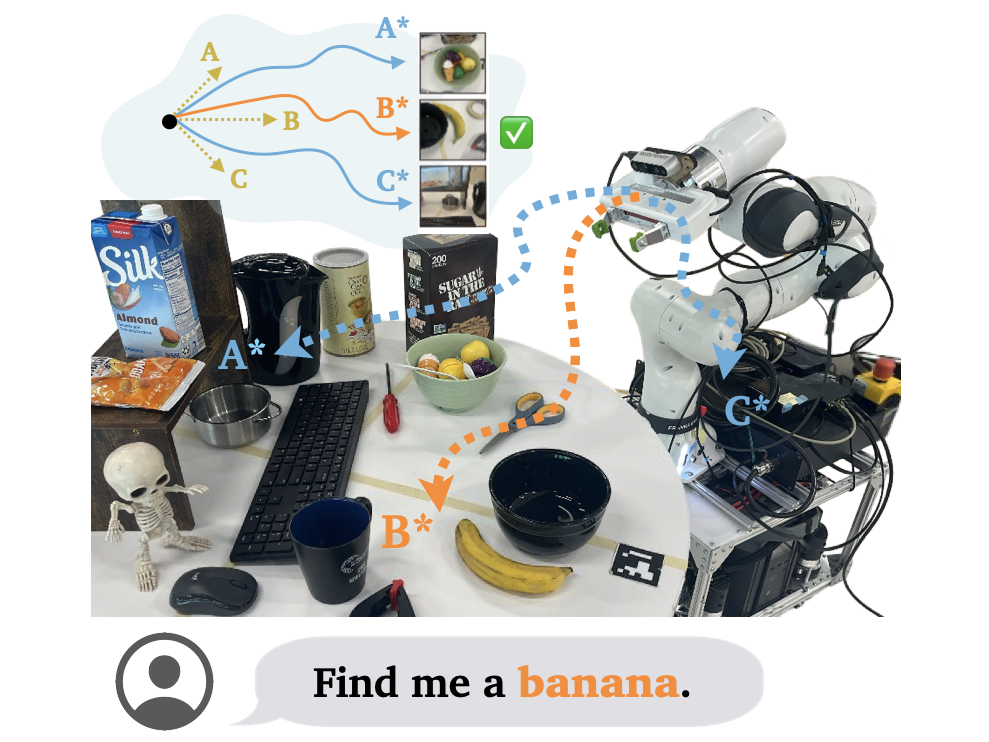
Conference on Robot Learning (CoRL), 2025
🏆 Best Paper Award, RSS 2025 SWoMo and SemRob Workshops
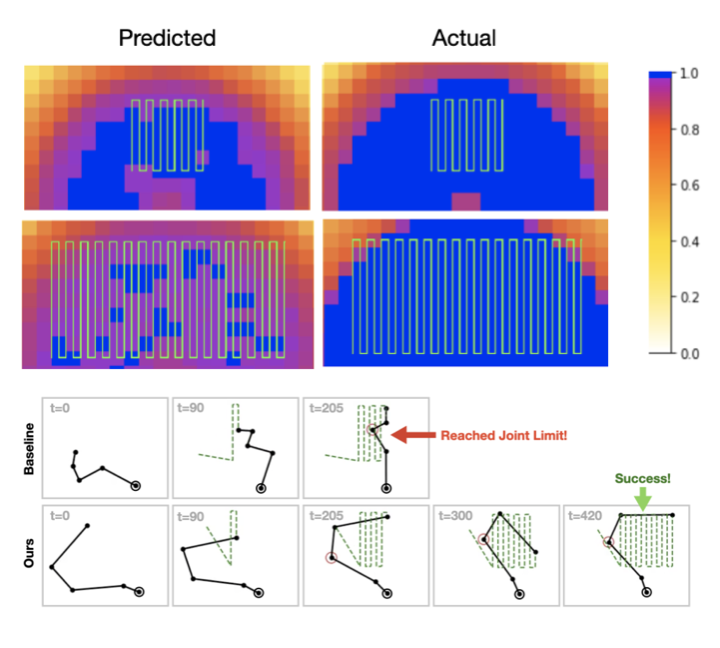
IEEE International Conference on Automation Science and Engineering (CASE), 2025
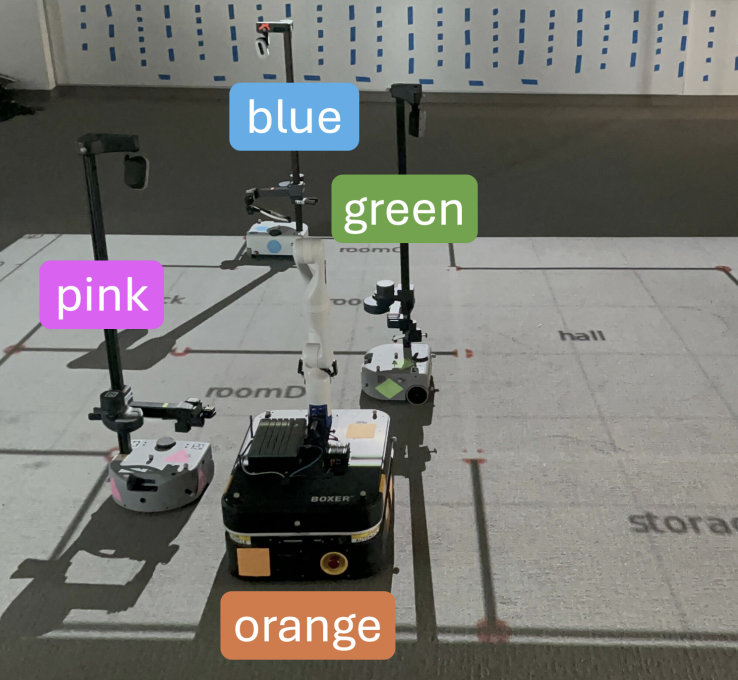
IEEE International Symposium on High-Performance Computer Architecture (HPCA), 2024